Various biotic indices have been used to assess the condition of aquatic macroinvertebrate communities in agricultural watersheds. We collected 171 samples of benthic macroinvertebrates from 57 stream sites on three forks of an agricultural watershed in southeastern Minnesota, USA, and compared the abilities of various diversity, taxa richness, and multi-metric indices to evaluate invertebrate community health and/or level of impairment. Total invertebrate abundance (sample count), total taxa richness, Ephemeroptera-Plecoptera-Trichoptera (EPT) taxa richness, Simpson diversity, Shannon diversity, a regional benthic index of biotic integrity (BIBI), and the national Izaak Walton League’s Save Our Streams (SOS) rating score were all significantly correlated with one another. Total taxa richness, BIBI score, and SOS score displayed nearly identical influences within a principal components analysis (PCA) ordination. Only total abundance and the two diversities differed significantly among stream forks. When the distributions of sites among rating categories (poor or very poor to excellent) were compared for the various indices, nearly all indices rated community health differently from one another. In order from highest ratings to lowest ratings, the indices were: Simpson diversity, Shannon diversity, SOS score, total taxa richness, EPT taxa richness, and BIBI score. Taxa richness measures and the multi-metric BIBI appeared to rate stream health more realistically (i.e., mostly fair or poor site ratings with relatively few good to excellent) than either of the diversity indices or the SOS score (many good, very good, and excellent site ratings), suggesting that the choice of biotic index can significantly influence evaluations of stream communities in an agricultural watershed.
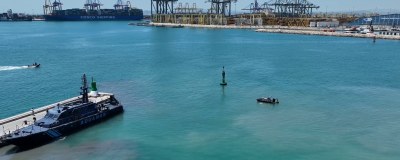
Underwater threats represent an increasing challenge to maritime safety and port security, demanding advanced solutions beyond traditional monitoring and inspection methods. This paper presents the development and field testing of a 5G-enabled Unmanned Surface Vehicle (USV) designed to enhance situational awareness and operational resilience against underwater risks in port environments. The study was conducted at the Port of Valencia, one of Europe’s most advanced smart ports equipped with a 5G Standalone (SA) network. By combining high-speed, low-latency communications with sensing technologies (including sonar modules, optical cameras, and environmental sensors), the proposed system enables real-time data exchange, remote operation, and continuous monitoring across surface and subsurface domains. Experimental trials validated the USV’s ability to detect submerged objects, support emergency response, and perform inspection and environmental monitoring tasks under stable 5G connectivity. These results demonstrate how the integration of unmanned surface platforms with next-generation communication networks can significantly strengthen the capacity to detect, assess, and mitigate underwater threats under teleoperated conditions.
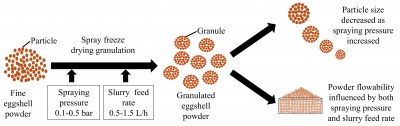
Eggshell powder is a sustainable calcium carbonate-based material with potential as a feedstock for binder jetting additive manufacturing. However, its irregular particles exhibit poor flowability and powder spreading characteristics. Although spray freeze drying granulation has previously been shown to improve the properties of eggshell powder, the influence of process variables on the resulting granules remains insufficiently understood. This study investigates the effects of spraying pressure and slurry feed rate on the properties of granulated eggshell powder. One-factor-at-a-time experiments were conducted to identify feasible ranges of these process variables, and a full factorial design of experiments with two replications was employed to evaluate the main and interaction effects of spraying pressure and slurry feed rate on particle size and flowability of granulated eggshell powder. Spraying pressure had a statistically significant effect on particle size, whereas slurry feed rate did not significantly affect particle size within the investigated range. Increasing spraying pressure resulted in smaller granules. Powder flowability was evaluated using both the Hausner ratio and repose angle. Both measures showed a significant interaction between spraying pressure and slurry feed rate, indicating that powder flowability depends on the combined effects of these two variables. The findings suggest that spraying pressure is the key variable governing particle size, while the combined influence of spraying pressure and slurry feed rate must be considered when controlling powder flowability. The resulting process–property relationships provide a basis for selecting spray freeze drying conditions for converting eggshell waste into more suitable granulated feedstock for binder jetting additive manufacturing.
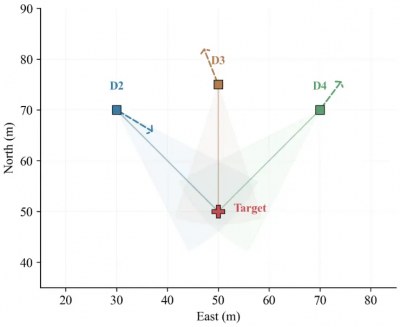
We address the problem of geolocating a static ground target from multiple low-cost Unmanned Aerial Vehicles (UAVs) equipped with monocular cameras and object detectors. Each drone generates large sequences of bearing-only measurements per flyover, but these are affected by per-drone GPS biases (systematic position errors specific to each UAV) that remain effectively constant over short trajectories. We propose a greedy selector that combines angular diversity and detection confidence to pre-filter measurements before Random Sample Consensus (RANSAC)-based robust fusion. Across 30 randomized simulation runs, the selector achieves mean accuracy comparable to full-pool RANSAC (2.34 m vs. 2.44 m) while reducing median processing time by 4.1× (393 ms vs. 1602 ms). Similar accuracy is observed against LO-RANSAC and PROSAC, with the selector remaining 4× to 35× faster. The selector also outperforms confidence-only and standard Fisher Information Matrix (FIM)-based subset baselines. A bias-aware FIM analysis via Schur-complement marginalization shows that the information contributed by repeated measurements from a single drone saturates under a shared position bias, explaining the single-drone concentration observed for these baselines. In the nominal setting, the angular-diversity proxy retains 99.7% of the bias-aware FIM objective and achieves localization error similar to direct FIM-based selection, while being 3.3× faster at the selection stage. Real flights with a low-cost quadrotor measure short-term GPS drift of 1.9–3.5 m over 10–63 min, supporting the assumed bias dynamics, and expose a failure mode in which persistent false positives capture the RANSAC consensus. Full-pool RANSAC shows slightly lower mean error at larger GPS-bias levels (σGPS ≥ 5 m), indicating that pre-selection is not preferable in every operating regime.
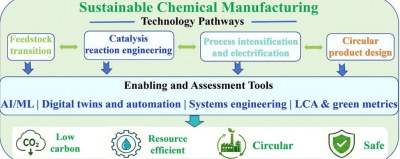
Green chemistry has evolved from a pollution-prevention concept into a practical framework for sustainable chemical manufacturing. To address climate change, resource depletion, and environmental pollution, chemical processes must be redesigned beyond end-of-pipe treatment toward low-carbon, safer, and circular manufacturing systems. This mini-review develops a systems framework for low-carbon and circular technologies in chemical manufacturing by organizing green chemical technologies into four interrelated pathways: feedstock transition, catalysis and reaction engineering, process intensification and electrification, and circular product design. Quantitative metrics such as atom economy, E-factor, process mass intensity, carbon footprint, and life-cycle assessment are emphasized as essential tools for evaluating real sustainability benefits and avoiding burden shifting. The review further highlights the enabling roles of biocatalysis, artificial intelligence, predictive modeling, digital twins, automation, and systems engineering as cross-cutting tools for translating technological advances into industrial-scale sustainable manufacturing. Future green chemical technology should move from isolated greener reactions toward integrated molecular, process, and system design for low-carbon and circular chemical manufacturing.