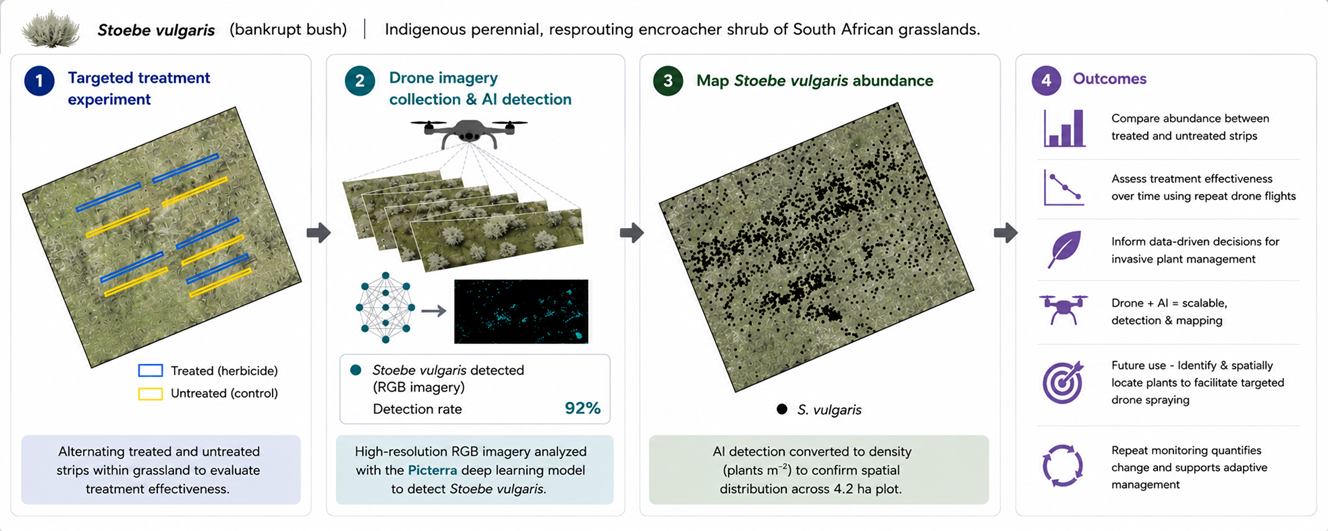
Stoebe vulgaris is a declared indigenous bush encroacher species in South Africa. It has invaded over 11 million ha of grasslands. It is commonly called bankrupt bush due to its ability to outcompete other indigenous forb and grass species, decreasing grazing capacity, biodiversity, and ecosystem functioning, eventually leading to financial ruin for farmers. Landowners are legally required to control the plant. A herbicide trial was set up in a severely encroached camp at Dundee Research Station in KwaZulu-Natal, South Africa, to test the effectiveness of metsulfuron-methyl (50 g active ingredient ha−1) in controlling S. vulgaris. Applying metsulfuron-methyl provided a significant long-term reduction in S. vulgaris cover over six years. However, effective monitoring and management strategies depend on knowledge of the spatial distribution and expansion patterns of invasive species. We evaluated the ability of UAV-based imagery and machine learning, using Picterra, to detect and map S. vulgaris, while determining the optimal parameters to maximise detection accuracy. The best season for image acquisition was late summer when vegetation was at peak growth and maturity, providing the best spectral distinction between species, under light overcast and mild wind conditions. We recommend careful consideration of the flight orientation to the solar angle. We achieved 92% detector accuracy, with multispectral imagery enhancing the discrimination of similarly coloured plants. Plants smaller than 10 cm were not detected by the model. Our approach, using high-resolution drone imagery and AI, is capable of individual plant detection suited to a farm scale. This opens the way for using advances in drone technology for targeted, spot-application of herbicide.
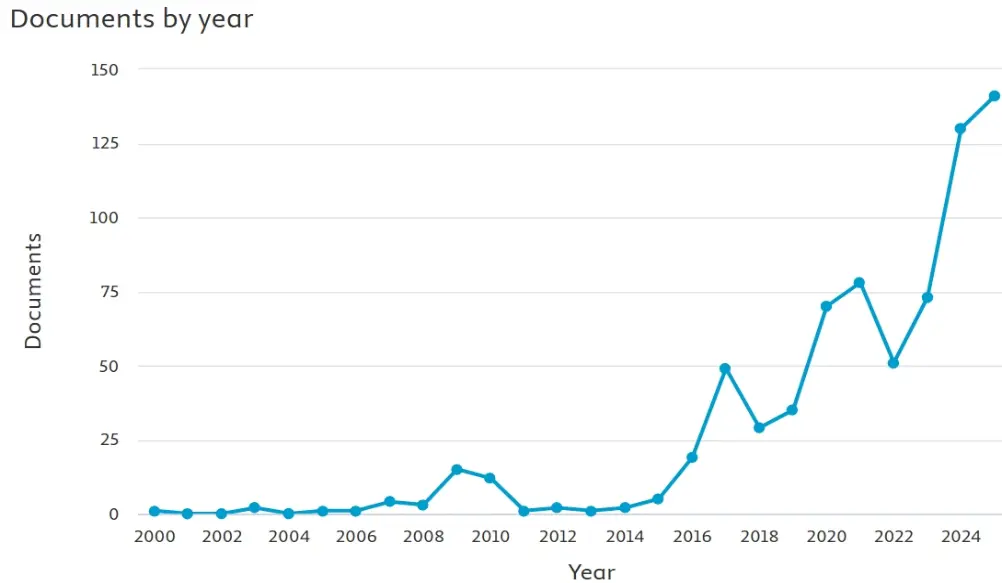
In this paper, we offer an overview of the published works dealing with fuzzy logic applied in drones, considering both theoretical works and applications in diverse areas, such as simulation, planning, and control of drones. The analysis was done considering all types of available publications, such as journal papers, chapters, and conference papers. The data were obtained by searching the Scopus database from Elsevier, which contains most of the world’s indexed publications across all areas of knowledge. Based on the obtained data, some conclusions were elaborated about the advances of fuzzy logic and its applications in drones, as well as interesting future trends for this area were delineated. In particular, as fuzzy logic has been evolving from type-1 to type-2 and more recently to type-3, the role of fuzzy systems in the area of drones is following the same evolution. We have to say this evolution has already happened in the area of controlling autonomous mobile robots, and we expect that this will also happen in the area of drones, as the navigation problem is similar to some extent. A limitation of the study is that we are only considering the evolution of fuzzy logic types, rather than other alternatives, such as intuitionistic or hesitant fuzzy theories, which could become more useful in the near future. Also, we are not studying hybrid approaches with fuzzy, like neuro-fuzzy or evolving fuzzy systems, which can be an interesting subject from the point of view of making a fuzzy system to become dynamic or adaptive.
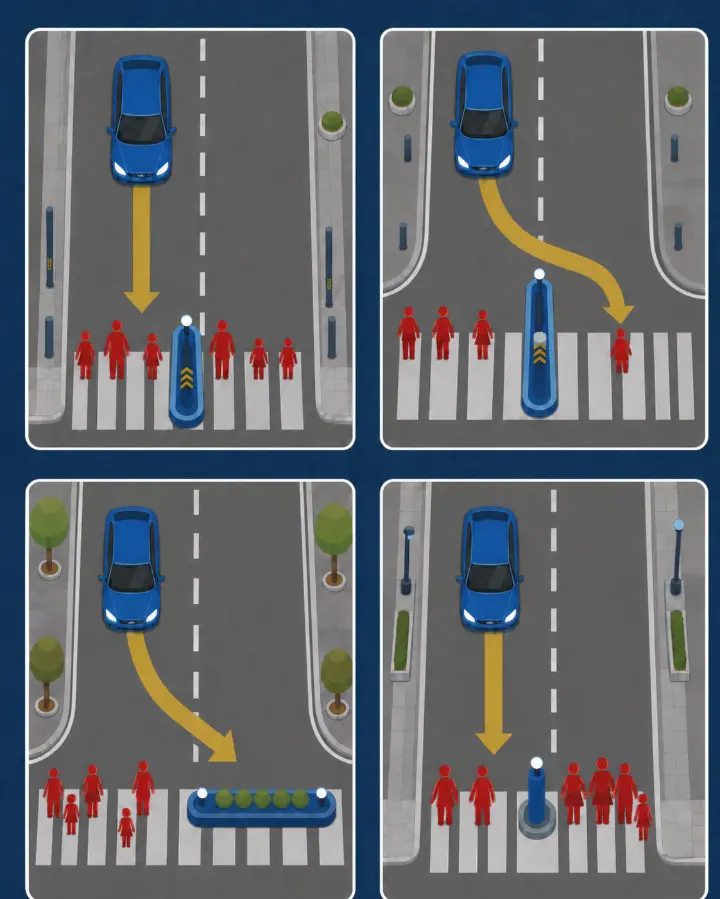
While rare, it is widely accepted that autonomous vehicles (AVs) will find themselves in dilemma scenarios involving vulnerable road users (VRUs). The ethics of these dilemma situations have been debated extensively in the context of trolley-problem-like scenarios. What has not been noted is the inherent unfairness implicit in many of these discussions, in which VRUs are seen as passive bystanders with no say in what befalls them. Rather than simply remaining still in a collision scenario, VRUs can (and often do) take action that needs to be accounted for. If we are to increase fairness on public roads, it is important that AVs communicate with VRUs. This paper presents a highly theoretical discussion on the possibility of using communication tools (such as the V2X system) and techniques (derived from the science of human-machine interaction) to support protective, risk-reducing responses from VRUs during inevitable AV collisions. The paper begins with a brief ethical exploration of fairness in the context of current debates surrounding AV collisions. We proceed to discuss possible technical solutions to AV-VRU communication, as well as the types of audio, visual, and tactile communication strategies necessary in critical scenarios.
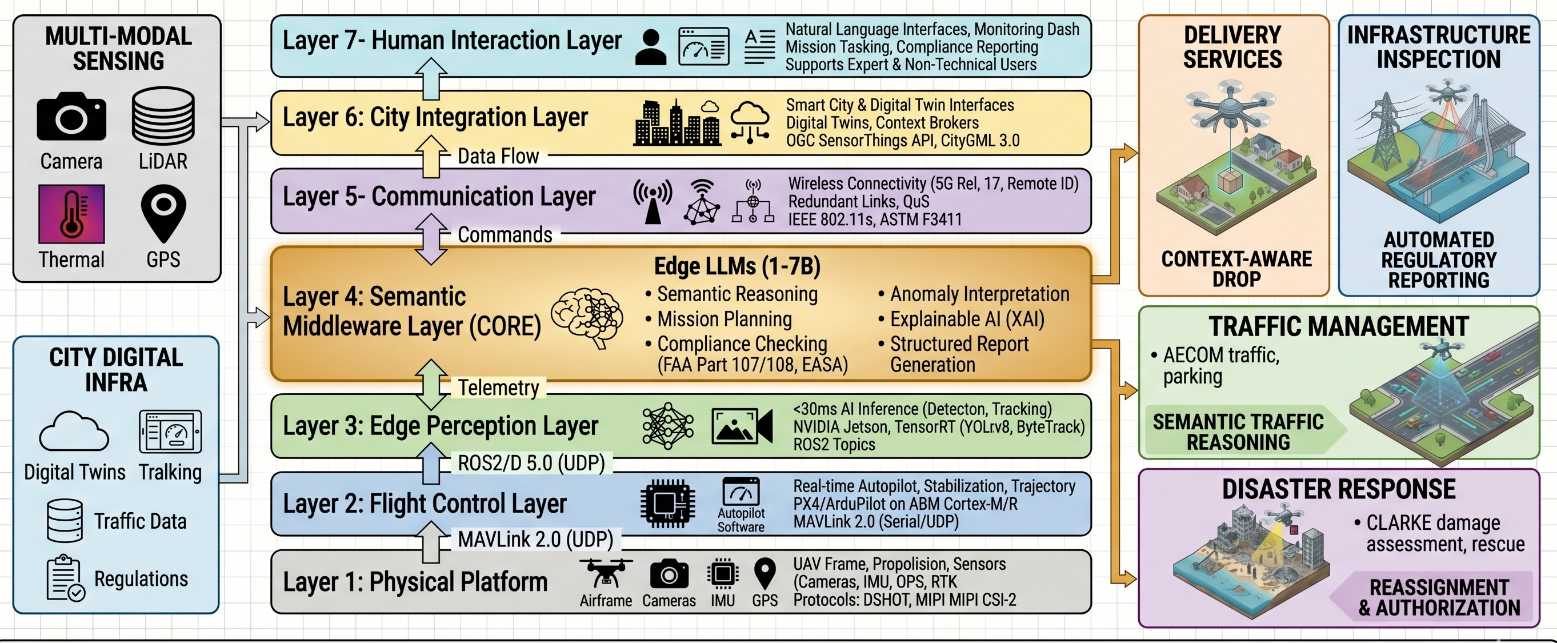
Despite a rapid rise of AI-powered Unmanned Aerial Vehicle (UAV) deployments in smart city environments, current surveys and frameworks lack a unified, protocol-level reference architecture that integrates multi-domain applications, edge AI perception, cognitive reasoning through Large Language Models (LLMs), and regulatory compliance within a single deployable specification. This study presents a comprehensive cross-domain review of AI-powered drone systems for traffic management, delivery, infrastructure inspection, disaster response, and environmental monitoring. The study introduces COMPASS (Cognitive Operations Model for Programmable Autonomous Smart-city Systems), a novel seven-layer technical reference architecture that describes communication protocols (MAVLink 2.0, ROS2/DDS, MQTT 5.0, and NGSI-LD), edge computing hardware recommendations for five drone payload tiers, and quantified performance requirements for safety-critical operations. The key feature of COMPASS is its LLM-based Semantic Middleware Layer, which allows for context-aware decision-making, natural human-drone interaction, and regulatory compliance verification. Comparing COMPASS to many other frameworks reveals that it is the only architecture to simultaneously provide multi-domain coverage, protocol-level specifications, hardware recommendations, LLM integration, and empirically verified benchmarks.
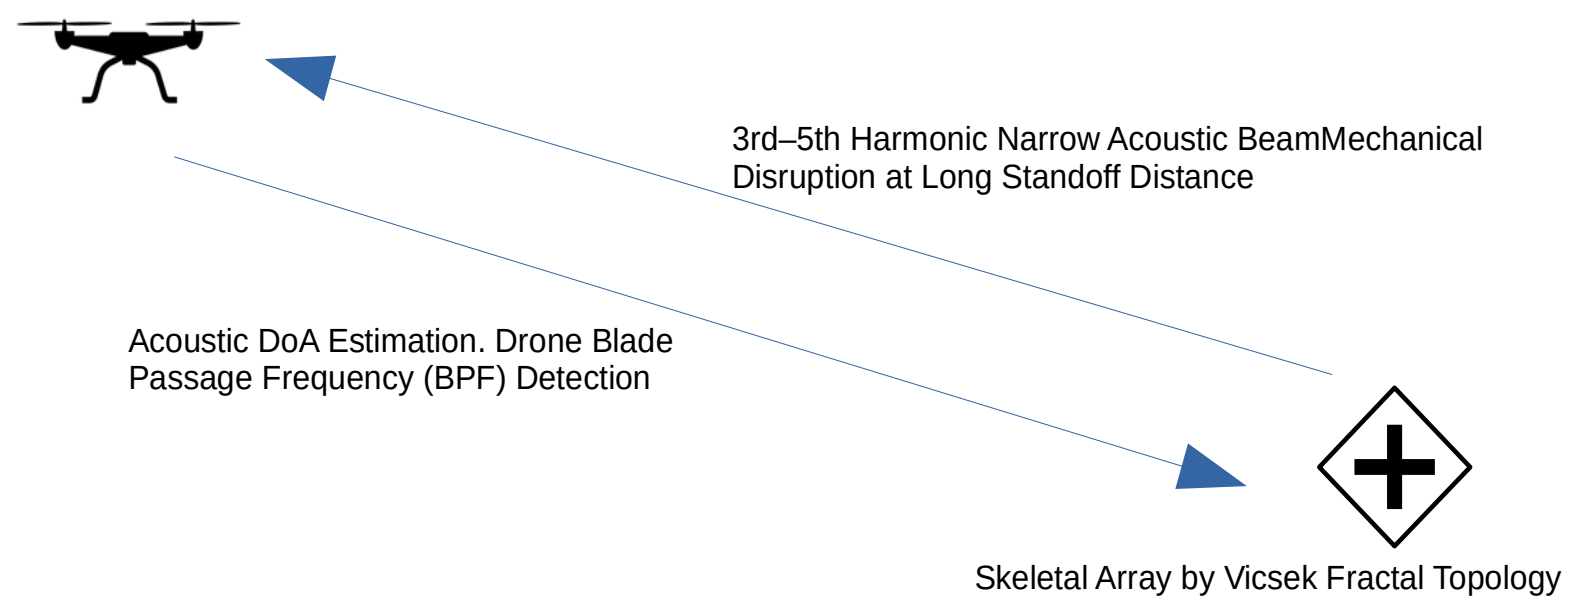
Acoustic waves can affect two important components of multi-rotor drones, more formally called multi-rotor unmanned aerial vehicles (UAV). The first is located in the electronic board, the so-called IMU (Inertial Measurement Unit), which can be influenced by intense sound waves at resonant frequency. The second is the motor-propeller unit of drones. Multi-rotor drones generate low-frequency acoustic emissions during flight; if external acoustic waves achieve resonance with these blade-induced vibrations, they can cause structural fatigue or mechanical failure in the motor-propeller unit. The paper addresses the following issues: first, the influence of resonant frequency sound waves on these two design elements and their performance evaluation; second, the feasibility of an integrated counter-UAV system comprising acoustic Direction of Arrival (DoA) estimation and Blade Passage Frequency (BPF) detection; and third, a new solution for a long-range directional sound effector. This proposed solution includes determining the operating frequency as the 3rd to 5th harmonics of the BPF. Furthermore, it introduces a new concept that, instead of using a standard array of sound drivers, utilizes a limited quantity of powerful drivers arranged skeletally according to a Vicsek fractal topology. This configuration generates a powerful, needle-like acoustic beam capable of delivering effective mechanical disruption multi-rotor drones at long ranges.
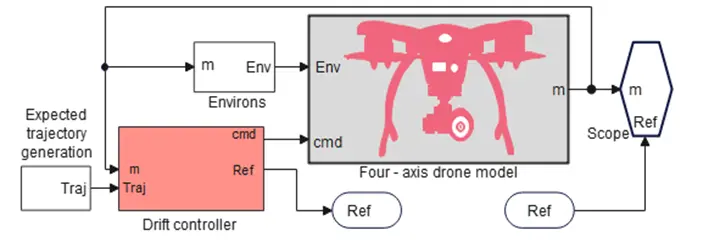
In this study, the trajectory planning and control problem for quadrotor unmanned aerial vehicles (UAVs) in logistics-oriented delivery scenarios. A smooth trajectory generation method based on spline curves is proposed to ensure continuous, stable, and feasible flight paths for quadrotor UAVs under dynamic constraints. The proposed method focuses on general UAV path planning rather than a specific express delivery optimization problem. A simulation platform is developed to evaluate the effectiveness of the trajectory planning and control framework, where a PID-based controller is implemented for trajectory tracking and attitude stabilization. The performance of the proposed method is validated through two representative emergency delivery scenarios, demonstrating accurate path tracking and stable flight behavior under environmental disturbances. The results indicate that the proposed framework provides a reliable simulation tool for UAV trajectory planning and control analysis, contributing to general UAV motion planning research rather than a specific delivery optimization formulation.
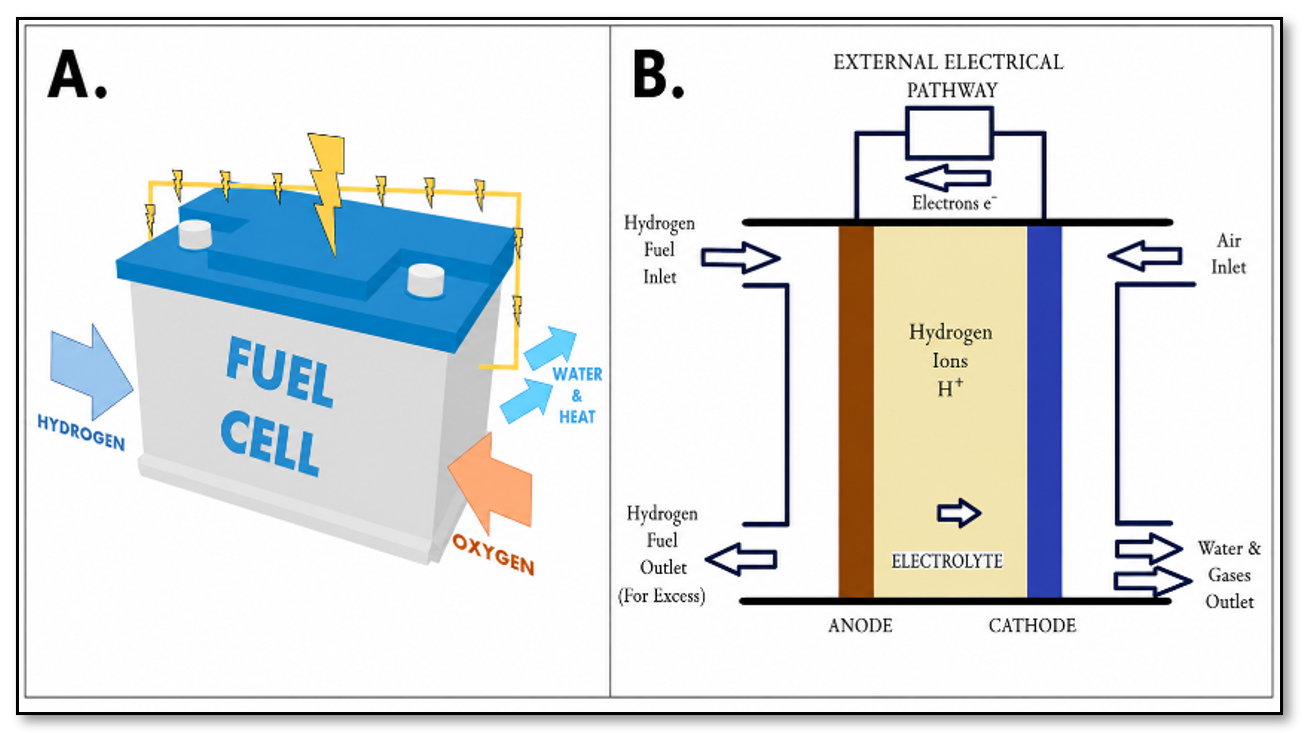
Unmanned aerial vehicles (UAVs) are increasingly used in applications such as agriculture, logistics, mapping, surveillance, and environmental monitoring. However, the limited battery endurance continues to restrict mission duration and operational range. This review examines two sustainable propulsion alternatives, hydrogen fuel cells and solar-powered systems, based on findings reported in the literature. Evidence from peer-reviewed studies, experimental demonstrations, and industrial reports published between 2009 and 2024 is considered. Key parameters, including endurance, payload capacity, and operational altitude, are compared, along with practical aspects such as hydrogen storage, thermal management, and energy control systems. The available data suggest that hydrogen fuel cell (HFC) drones are better suited for low to mid-altitude missions requiring higher payload and rapid refueling. Solar-powered drones are more effective for long-endurance and high-altitude applications under favorable solar conditions. Future developments are expected to focus on hybrid propulsion systems, improved materials, and more efficient energy management strategies.
Although autonomous functioning facilitates the deployment of robotic systems in operating domains that support limited to no human oversight, establishing correspondence between task requirements and a system’s autonomous performance is still an open challenge. Several techniques for characterizing operating domains and/or quantifying autonomy have been proposed over the last three decades, however, to our knowledge, these have no discernment of sub-mode features of variation of autonomy, and some are based on metrics that are susceptible to the Goodhart’s law. This paper introduces a capability-based quantitative autonomy assessment framework for fully autonomous systems. The formulation of the framework started by establishing robot task characteristics from which three autonomy metrics, namely an essential capability set, reliability, and responsiveness, were derived. The characteristics were founded on the realization that robots ultimately replace human skilled workers, from which a relationship between human job and robot task characteristics was established. Additionally, mathematical formulations relating metrics to autonomy are also presented. To emphasize the fact that autonomy is not just a question of existence, but also one of performance of a capability, the framework represents it as a two-part measure, of level and degree of autonomy. Usage of the framework has been demonstrated on two case studies, namely an autonomous vehicle at an on-road dynamic driving task and the DARPA Subterranean Challenge analysis. The framework provides not only a tool for quantifying autonomy and monitoring the integrity of systems, but also a regulatory interface and common language for autonomous systems’ developers and users.
We address the problem of geolocating a static ground target from multiple low-cost Unmanned Aerial Vehicles (UAVs) equipped with monocular cameras and object detectors. Each drone generates large sequences of bearing-only measurements per flyover, but these are affected by per-drone GPS biases (systematic position errors specific to each UAV) that remain effectively constant over short trajectories. We propose a greedy selector that combines angular diversity and detection confidence to pre-filter measurements before Random Sample Consensus (RANSAC)-based robust fusion. Across 30 randomized simulation runs, the selector achieves mean accuracy comparable to full-pool RANSAC (2.34 m vs. 2.44 m) while reducing median processing time by 4.1× (393 ms vs. 1602 ms). Similar accuracy is observed against LO-RANSAC and PROSAC, with the selector remaining 4× to 35× faster. The selector also outperforms confidence-only and standard Fisher Information Matrix (FIM)-based subset baselines. A bias-aware FIM analysis via Schur-complement marginalization shows that the information contributed by repeated measurements from a single drone saturates under a shared position bias, explaining the single-drone concentration observed for these baselines. In the nominal setting, the angular-diversity proxy retains 99.7% of the bias-aware FIM objective and achieves localization error similar to direct FIM-based selection, while being 3.3× faster at the selection stage. Real flights with a low-cost quadrotor measure short-term GPS drift of 1.9–3.5 m over 10–63 min, supporting the assumed bias dynamics, and expose a failure mode in which persistent false positives capture the RANSAC consensus. Full-pool RANSAC shows slightly lower mean error at larger GPS-bias levels (σGPS ≥ 5 m), indicating that pre-selection is not preferable in every operating regime.
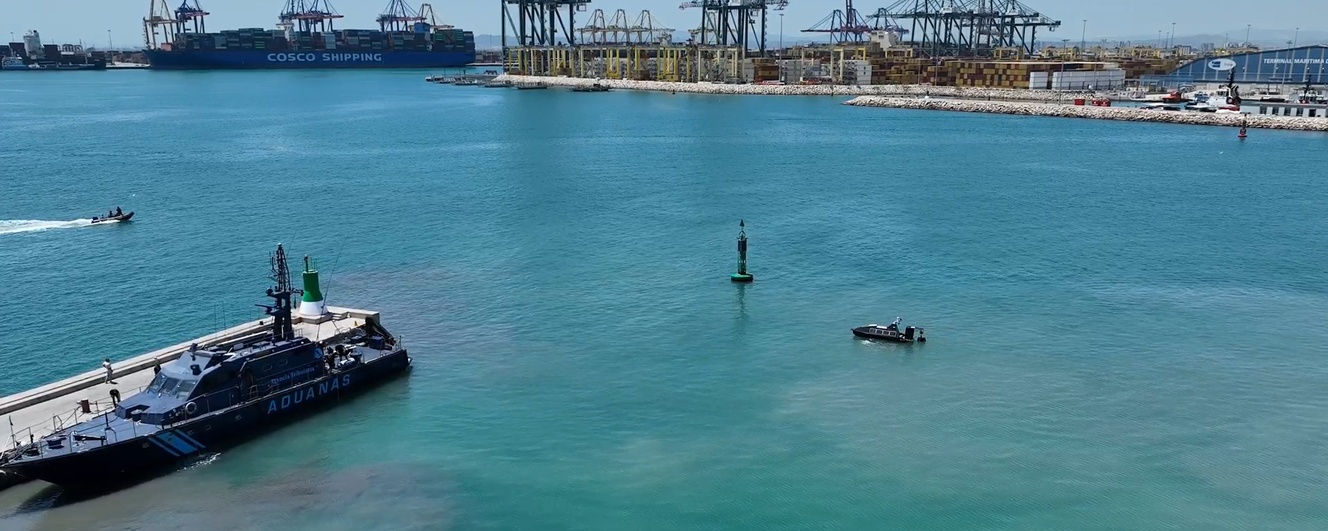
Underwater threats represent an increasing challenge to maritime safety and port security, demanding advanced solutions beyond traditional monitoring and inspection methods. This paper presents the development and field testing of a 5G-enabled Unmanned Surface Vehicle (USV) designed to enhance situational awareness and operational resilience against underwater risks in port environments. The study was conducted at the Port of Valencia, one of Europe’s most advanced smart ports equipped with a 5G Standalone (SA) network. By combining high-speed, low-latency communications with sensing technologies (including sonar modules, optical cameras, and environmental sensors), the proposed system enables real-time data exchange, remote operation, and continuous monitoring across surface and subsurface domains. Experimental trials validated the USV’s ability to detect submerged objects, support emergency response, and perform inspection and environmental monitoring tasks under stable 5G connectivity. These results demonstrate how the integration of unmanned surface platforms with next-generation communication networks can significantly strengthen the capacity to detect, assess, and mitigate underwater threats under teleoperated conditions.